Custom firmware for the Anycubic Kobra 3 toolhead: keeping the original RS-232 link
We are developing custom firmware and a communication protocol for the original GD32F303 toolhead. Our first milestone is a safe, bidirectional UART link with a Raspberry Pi 4.
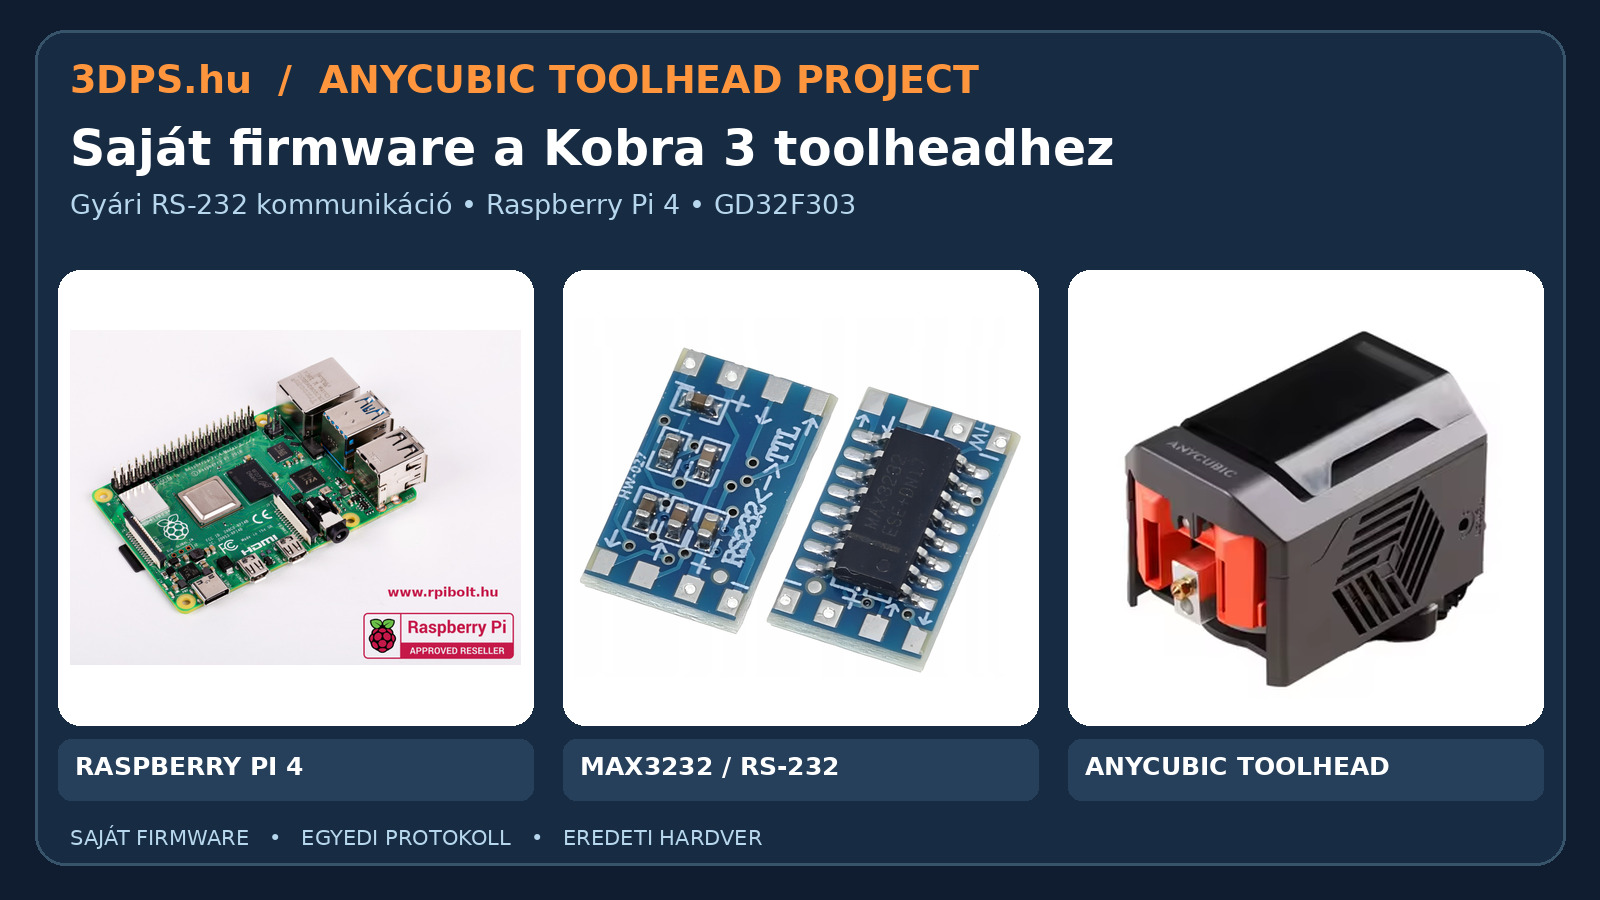
Our Anycubic Kobra 3 toolhead reverse-engineering project is entering a new phase: we are designing custom firmware and a custom communication protocol for the original GD32F303CBT6 microcontroller. The goal is to retain the original connectors and RS-232 hardware while controlling the toolhead with our own software.
Why keep the original communication path?
The original toolhead communication path includes an RS-232 transceiver. Earlier investigation suggests that the MCU UART on PA9 and PA10 may provide the link. This would avoid soldering a separate USB data cable to the MCU in the final design. The original Type-C connector must not be treated as a standard USB data port in this configuration.
First step: standalone UART diagnostics
The planned first firmware version would use the GD32F303 USART0 peripheral (PA9 TX, PA10 RX) at 115200 baud, 8N1, and accept simple PING, INFO and STATUS diagnostic commands. These are intended only for the initial link test; the final protocol is planned to use versioned binary frames with integrity checks.
Raspberry Pi 4 as the development host
The Raspberry Pi 4 GPIO UART would provide the host-side interface. A separate 3.3 V-compatible MAX3232/SP3232 transceiver is needed to connect to the original RS-232 line. As that component is not yet available, we plan an initial direct 3.3 V UART test, but only after safely isolating the original RS-232 receiver output and verifying logic levels. Raspberry Pi UART pins must never be connected directly to RS-232 voltage-level signals.
Current progress
We previously established SWD access to the microcontroller, flashed experimental firmware and verified the flash contents by readback. This confirms programming access, not complete peripheral functionality. An initial diagnostic source-code draft for the custom firmware exists, but the full build, flash and bidirectional UART test are still pending.
Safety and next milestone
The heater, extruder motor and fans will remain inactive during initial communication tests. The next milestone is reliable PING/PONG communication, followed by mapping the peripheral pins and individually testing motor, heater and sensor control with appropriate safeguards. Future Klipper integration would require a separate host-side adapter and precise motion timing.